JY
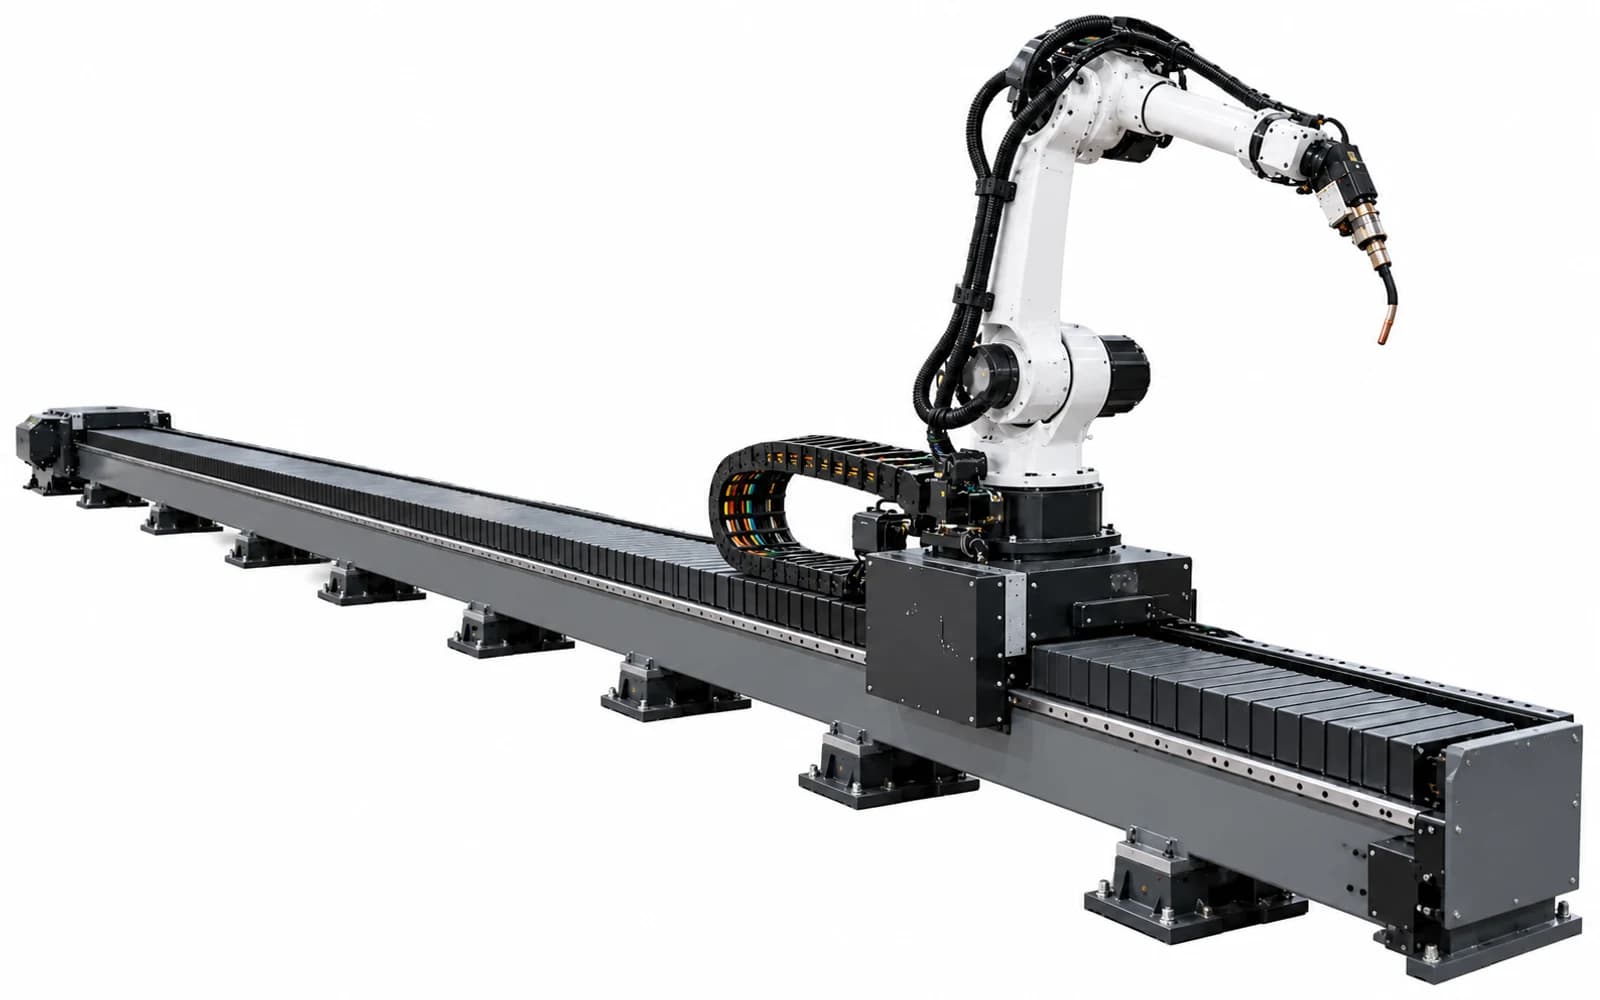
JY-100 Robot Seventh-Axis Track
The JY-100 family extends a robot between work areas using semi-enclosed, enclosed or bellows-protected track arrangements. Its published family table lists a configured 0.5–6 t load range and 0–60 m/min travel speed.
Request a project quoteChoose the configuration around your production task.
The JY-100 family extends a robot between work areas using semi-enclosed, enclosed or bellows-protected track arrangements. Its published family table lists a configured 0.5–6 t load range and 0–60 m/min travel speed. Those endpoints describe a configuration range, not a promise that every load, stroke and speed can be combined.
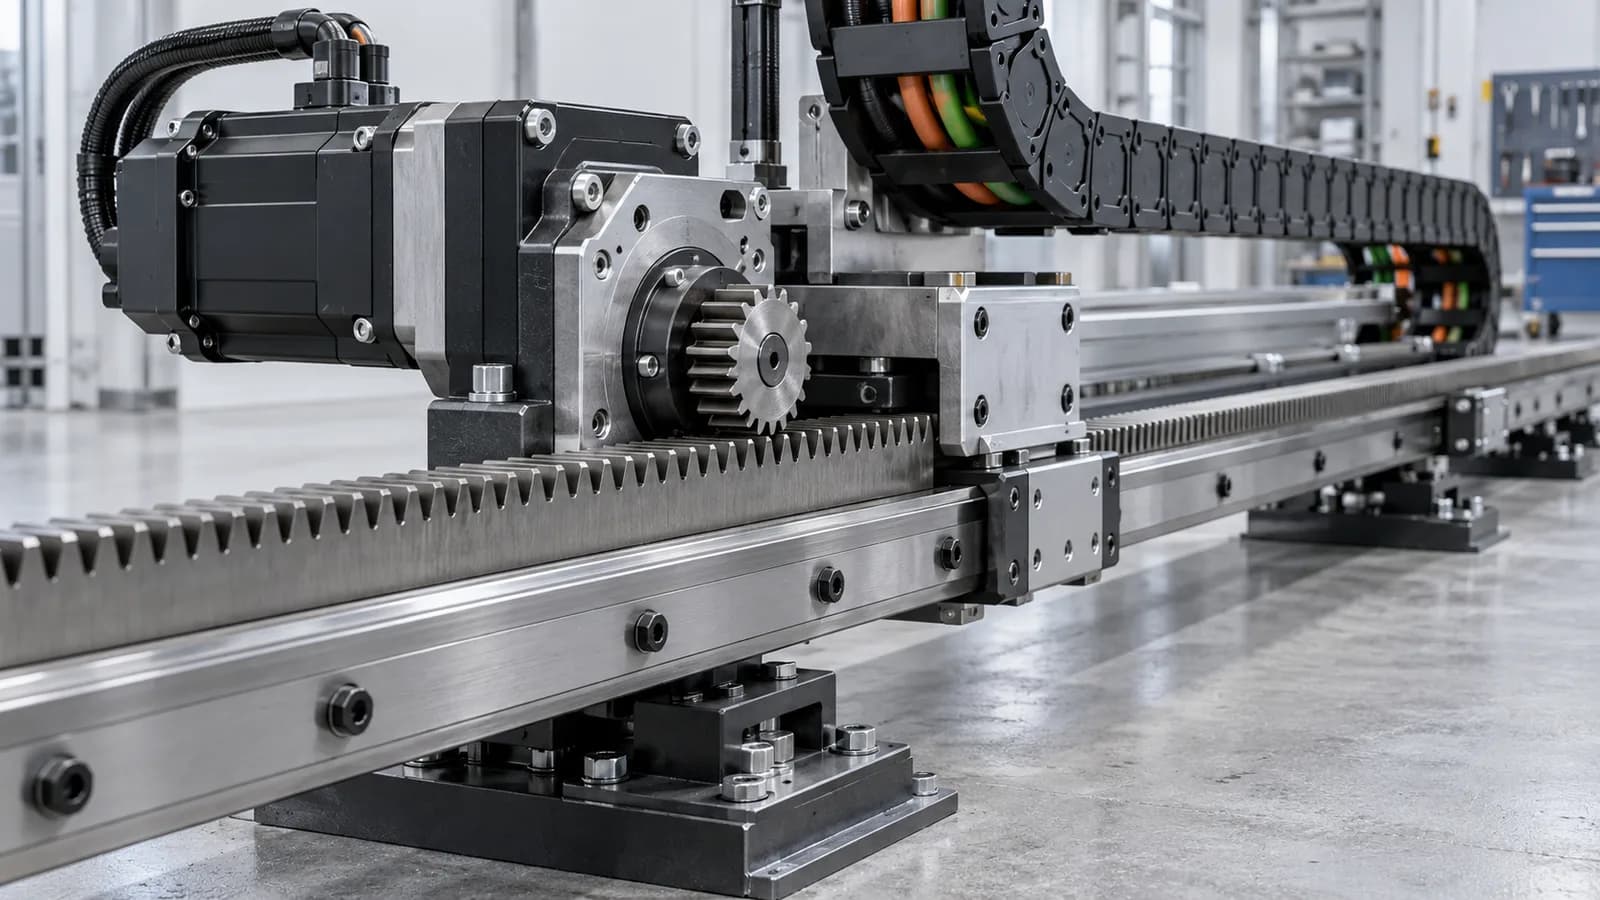
A linear axis or gantry earns its place when it connects the required work areas without turning transfer into the bottleneck. Map every pickup, process and handoff position, not just the distance between the first and last stations. The moving load includes the robot or gripper, part, adapters and moving service equipment; acceleration and overhang change the mechanical demand. Define who supplies the motor, drive, feedback, cable carrier, lubrication and homing hardware. An external robot axis also needs a controller-specific integration decision: travel between stations is different from coordinated process motion. For overhead equipment, reserve access for erection, lifting and later component replacement. Foundation reactions, anchoring, end stops, cable bend radius and safe recovery after a stop belong in the layout review. Compare quotes using the same useful stroke, loaded motion and handoff conditions, not a headline speed alone.
Published specifications
Published selection values: Models: JY-100 Semi-enclosed / JY-100 Bellows / JY-100 Enclosed · Configured load range: 0.5-6T (configured) · Position repeatability: ±0.05mm · Travel speed: 0-60m/min. Read each model row separately; family ranges are not combined ratings.
Compare the model before you compare the quote.
| Model / arrangement | Published selection parameters |
|---|---|
| JY-100 Semi-enclosed |
|
| JY-100 Bellows |
|
| JY-100 Enclosed |
|
Which configuration fits the task?
Floor track
Extend an arm between stations; reserve the entire carriage envelope.
Overhead gantry
Approach from above; define supports, Z clearance and service access.
Multiple moving axes
Specify each independent carriage and collision/restart sequence.
Selection and RFQ matrix
Useful stroke and all loaded handoff positions · Moving mass, overhang and duty sequence · Foundation, service routing and controller integration
| What to confirm | Selection inputs | Project action |
|---|---|---|
| Useful stroke and all loaded handoff positions | Models: JY-100 Semi-enclosed / JY-100 Bellows / JY-100 Enclosed · Configured load range: 0.5-6T (configured) · Position repeatability: ±0.05mm · Travel speed: 0-60m/min | Select the exact model and define the loaded operating conditions. |
| Moving mass, overhang and duty sequence | Current part drawing, process sequence and layout. | Agree the motion, access and changeover checks before ordering. |
| Foundation, service routing and controller integration | Existing equipment versions, service connections and access limits. | Assign an owner for each interface and its acceptance test. |
| Delivery and acceptance scope | Itemized equipment, integration, freight and site-work proposal. | Agree inclusions, exclusions, testing and handover responsibilities. |
From requirements to equipment handover.
- 01Part and process inputs
- 02Model and configuration selection
- 03Interfaces and layout
- 04Quotation and responsibilities
- 05Testing and handover
Start from the production task.
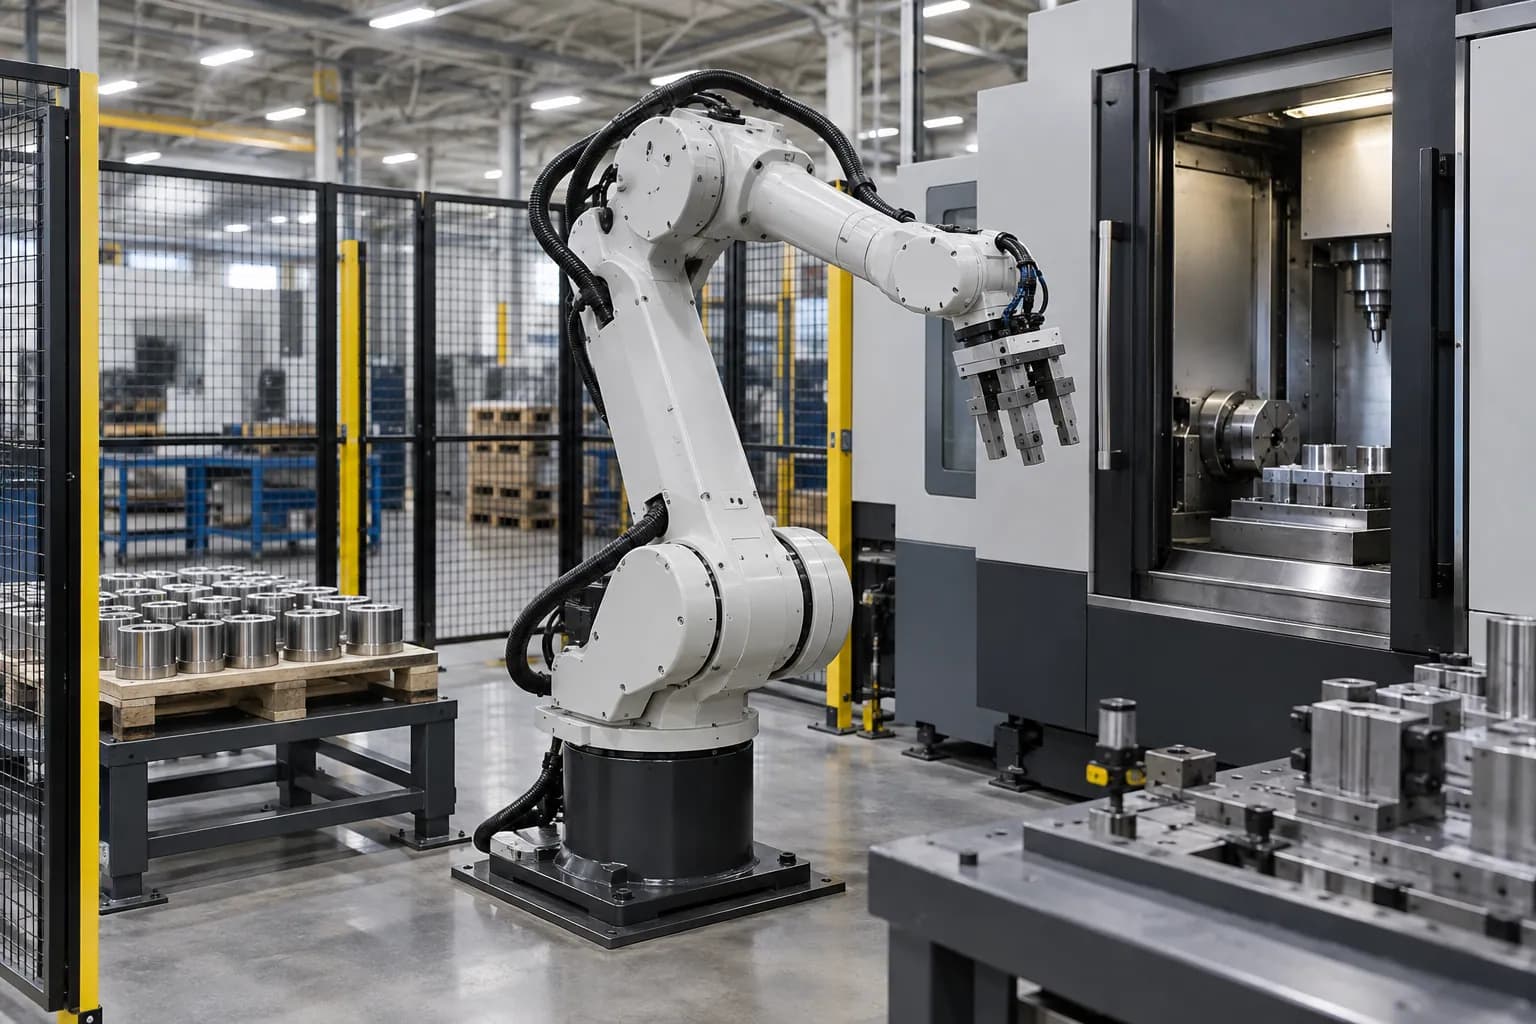
- 01Machine tending
- 02Part transfer
See the equipment in its decision context.
Questions before you request a quote
01How should I select JY-100 Robot Seventh-Axis Track?+
Compare the listed arrangements: JY-100 Semi-enclosed / JY-100 Bellows / JY-100 Enclosed. Start with useful stroke and all loaded handoff positions, then define moving mass, overhang and duty sequence. Use the model table to shortlist equipment and the project drawing to decide the final configuration. A family name alone does not define the supplied package.
02Can a track become a coordinated robot axis?+
That depends on the exact controller, software, drive, feedback and kinematic configuration. Identify whether the requirement is station-to-station indexing or simultaneous process motion, then agree the integration package and loaded acceptance test. No controller or brand compatibility is assumed from the track model alone.
03What determines the equipment quotation?+
A robot seventh axis track quotation depends on the selected model or arrangement, tooling, control package, services, safeguards, testing and delivery scope. Separate equipment-only supply from complete-cell integration. Confirm quantity, destination, documentation, packaging and site work in the written proposal; prices and availability are not inferred from catalog values.
04Can the quotation include integration and commissioning?+
The proposal can define equipment sourcing and partner-supported integration as separate work packages. Specify mechanical and electrical installation, software, commissioning, training, FAT/SAT, spares and service ownership. Existing robot/controller versions and site utilities must be identified before an interface or installation commitment is agreed.
05What should I send to request a project proposal?+
Send useful stroke and all loaded handoff positions; moving mass, overhang and duty sequence; foundation, service routing and controller integration. Add drawings, quantity, destination and the acceptance method. Identify existing equipment by model, nameplate and software revision. These inputs allow the technical proposal, interfaces and commercial exclusions to be discussed together.
Turn the product shortlist into a complete scope.
Send the workpiece, process, drawings, output target and destination. We will align the equipment with the technical interfaces and commercial delivery path.