Robotic Welding
Configure robot, power source, torch, feeder, fixture, positioner, sensing and safety around the weld and workpiece.
Review ↗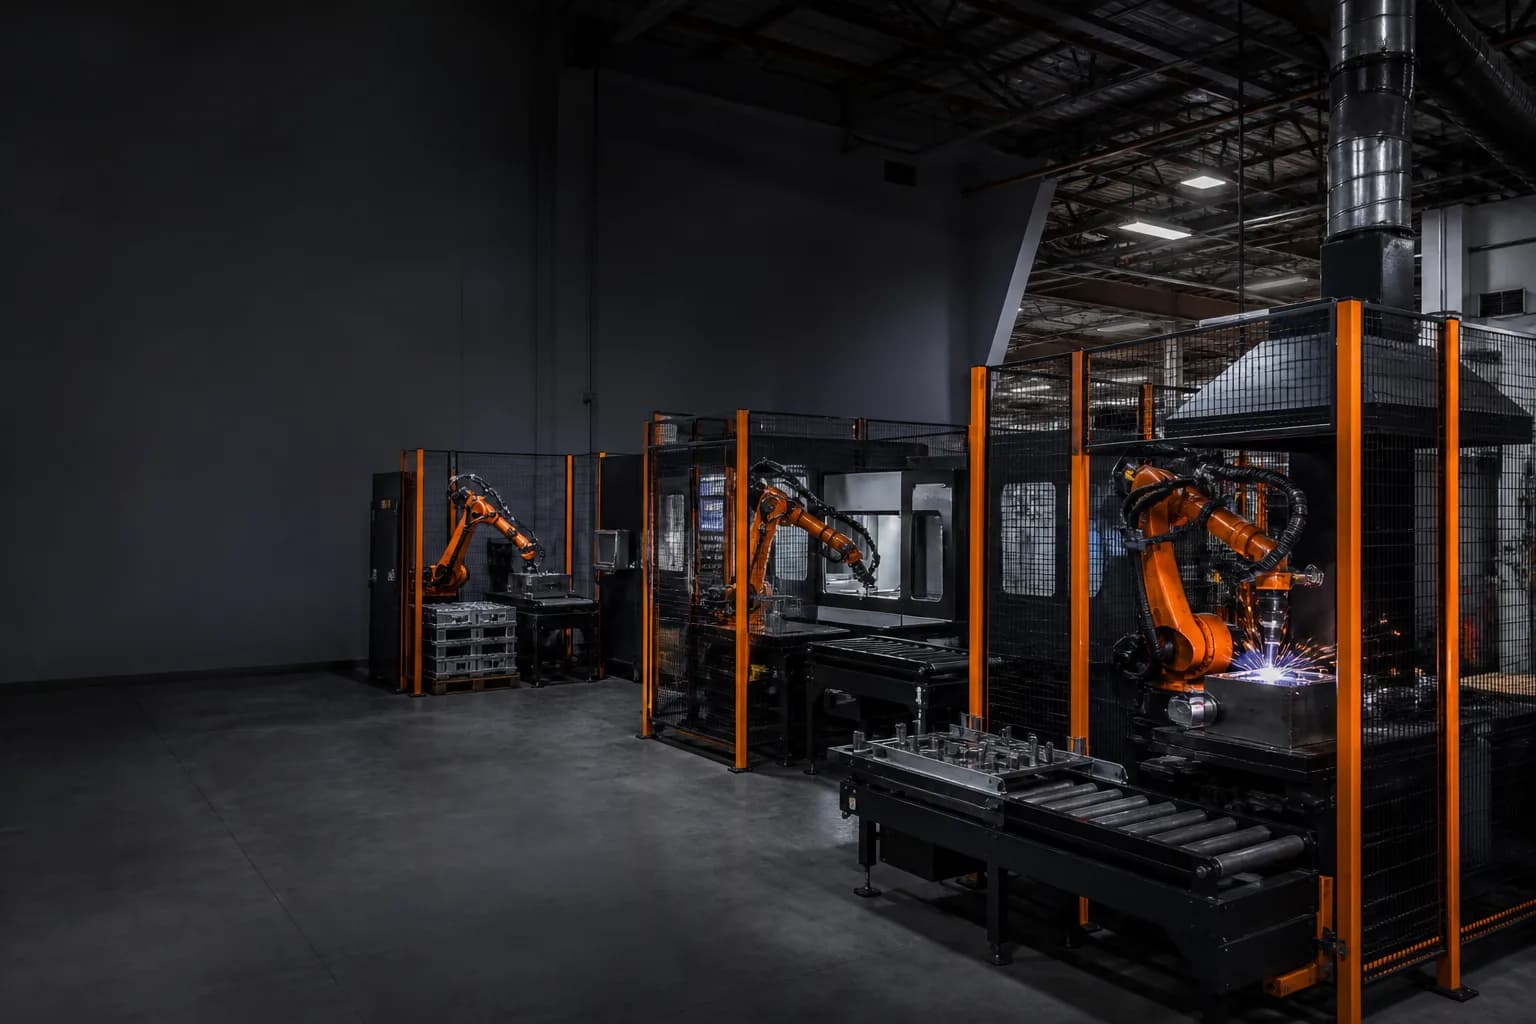
Start with the production bottleneck, then configure the robot, tooling, controls, safety and validation needed to change it.
Automation projects underperform when equipment is selected without a measurable target for uptime, throughput, quality or labor allocation.
Configure robot, power source, torch, feeder, fixture, positioner, sensing and safety around the weld and workpiece.
Review ↗Select the robot and EOAT from machine interface, door/fixture sequence, payload, reach, cycle and part presentation.
Review ↗Define pick, place, orientation, infeed/outfeed and buffer logic before selecting the robot.
Review ↗Coordinate tools, compliance, force/torque sensing, vision, fixtures and verification around the assembly process.
Review ↗Review total moving mass, center of gravity, moment, reach, throughput and handoff points.
Review ↗Match speed, product variation, detection, gripping and reject handling to an achievable cell concept.
Review ↗Treat vision as a calibrated process input: part presentation, lighting, tolerance, coordinate frames and recovery all matter.
Review ↗Describe the current operation, part and target. We will map the cell decisions that affect feasibility and investment.