Robotic Welding
Configure robot, power source, torch, feeder, fixture, positioner, sensing and safety around the weld and workpiece.
Review application ↗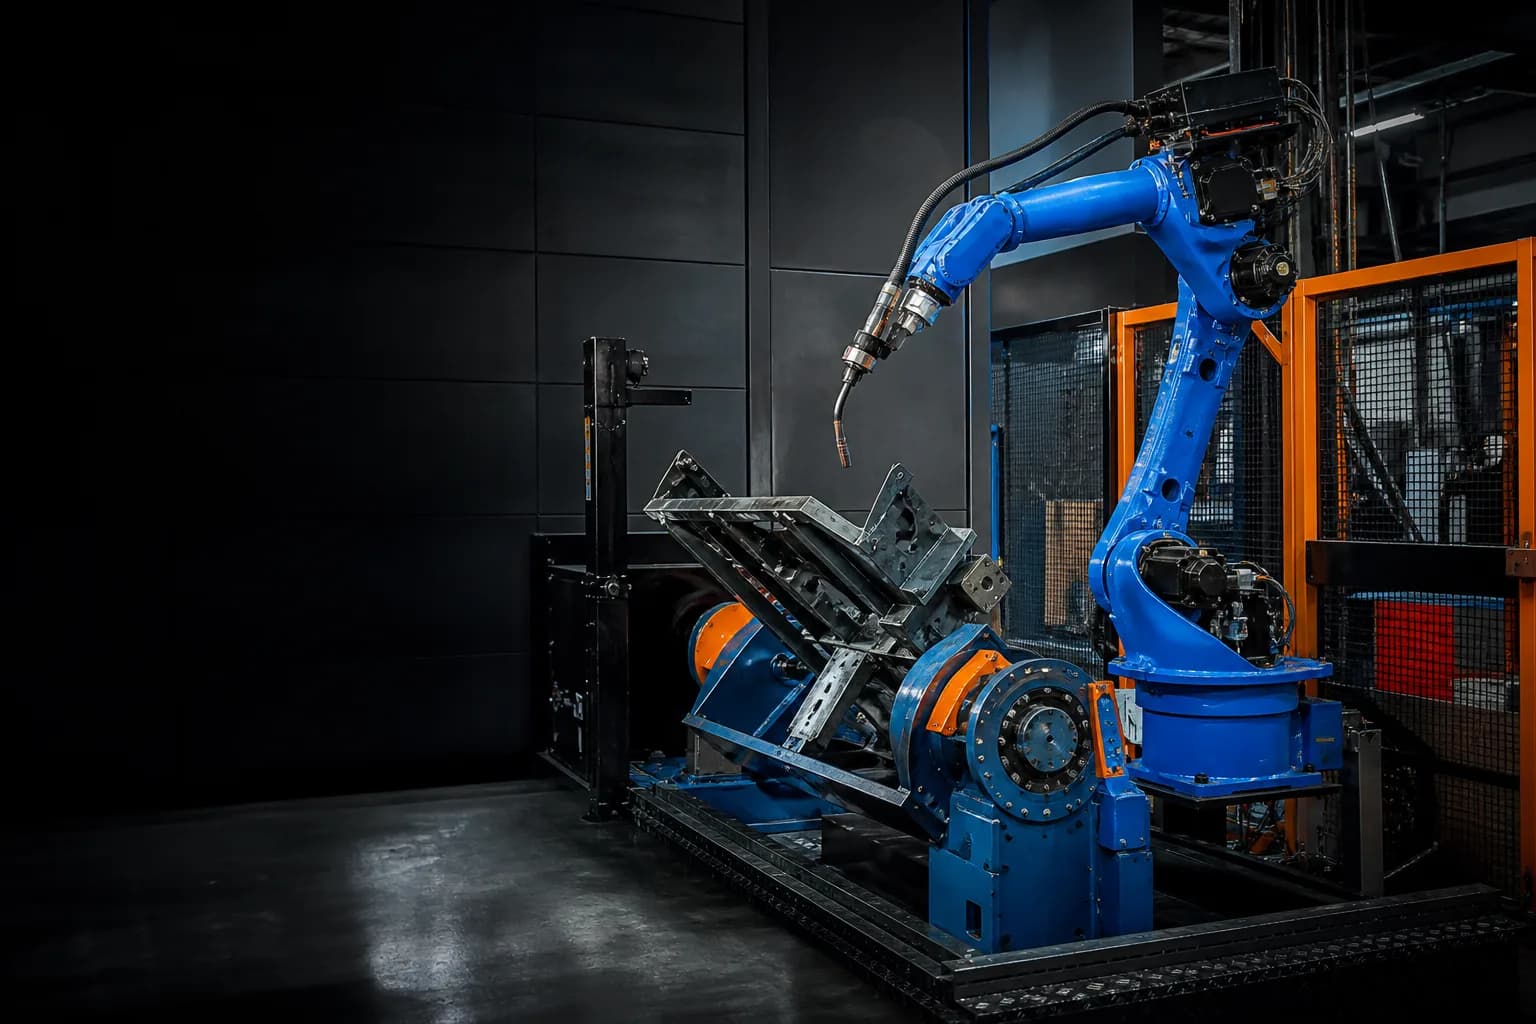
Compare Yaskawa AR, GP and YRC routes through the workpiece, application, controller, regional availability and complete system scope.
Selecting the robot series without the controller, tool, positioner, communication and regional supply route leaves the buying decision incomplete.
Industrial robots and controllers. TubeFrame Automation reviews current manufacturer documentation and project-specific availability before recommending a model or package.
Manufacturer catalog plates, translated selection logic and RFQ inputs are organized into a practical engineering guide.
Open the Yaskawa selection guide ↗Configure robot, power source, torch, feeder, fixture, positioner, sensing and safety around the weld and workpiece.
Review application ↗Select the robot and EOAT from machine interface, door/fixture sequence, payload, reach, cycle and part presentation.
Review application ↗Coordinate tools, compliance, force/torque sensing, vision, fixtures and verification around the assembly process.
Review application ↗Review total moving mass, center of gravity, moment, reach, throughput and handoff points.
Review application ↗Workpiece, motion, quality and cycle requirements establish the equipment class.
Payload, reach, mounting, interfaces and environment narrow the viable models.
Region, availability, support route and delivery scope are confirmed before quotation.
Documentation, spares, training and service ownership are recorded in the project scope.
Provide the application, workpiece, total moving mass, reach and access, process, target cycle, environment, destination and any site or preferred-brand standards. We use those inputs to identify a viable platform route and the unknowns that still need validation.
Send the preferred model or workpiece requirements to compare the viable robot and controller routes.