Robotic Welding
Configure robot, power source, torch, feeder, fixture, positioner, sensing and safety around the weld and workpiece.
Review application ↗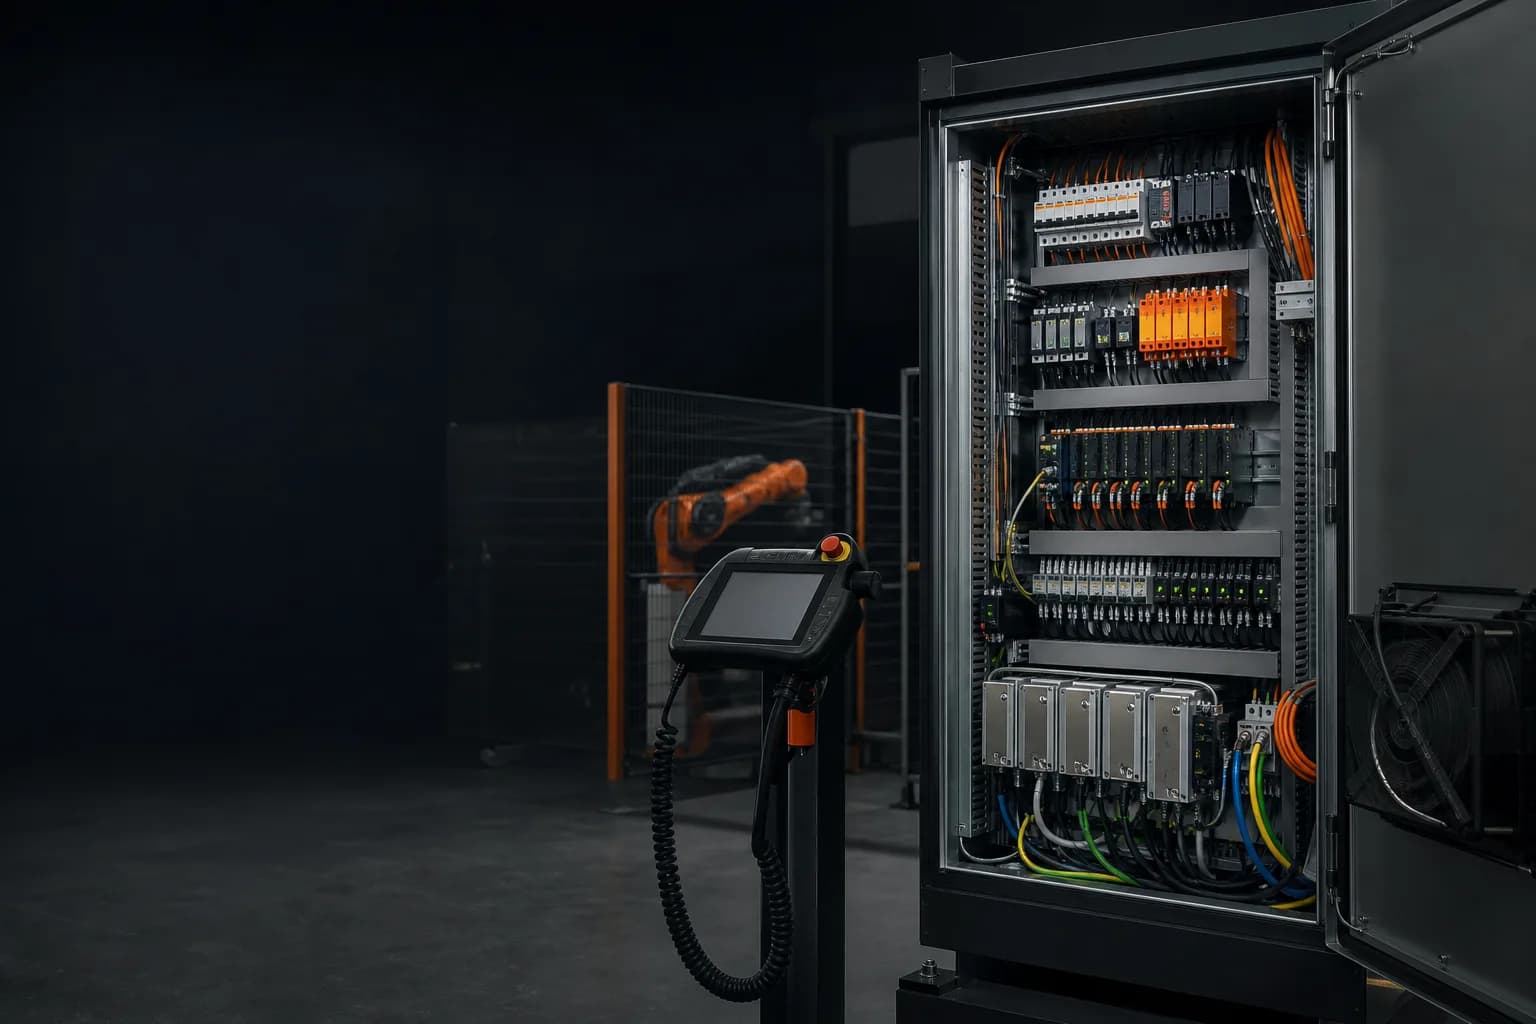
Check YRC1000 compatibility and interface scope across the selected robot, external axes, fieldbus, safety and application software.
Ordering by controller name alone can miss robot compatibility, installed software, network option, teach pendant or regional electrical requirements.
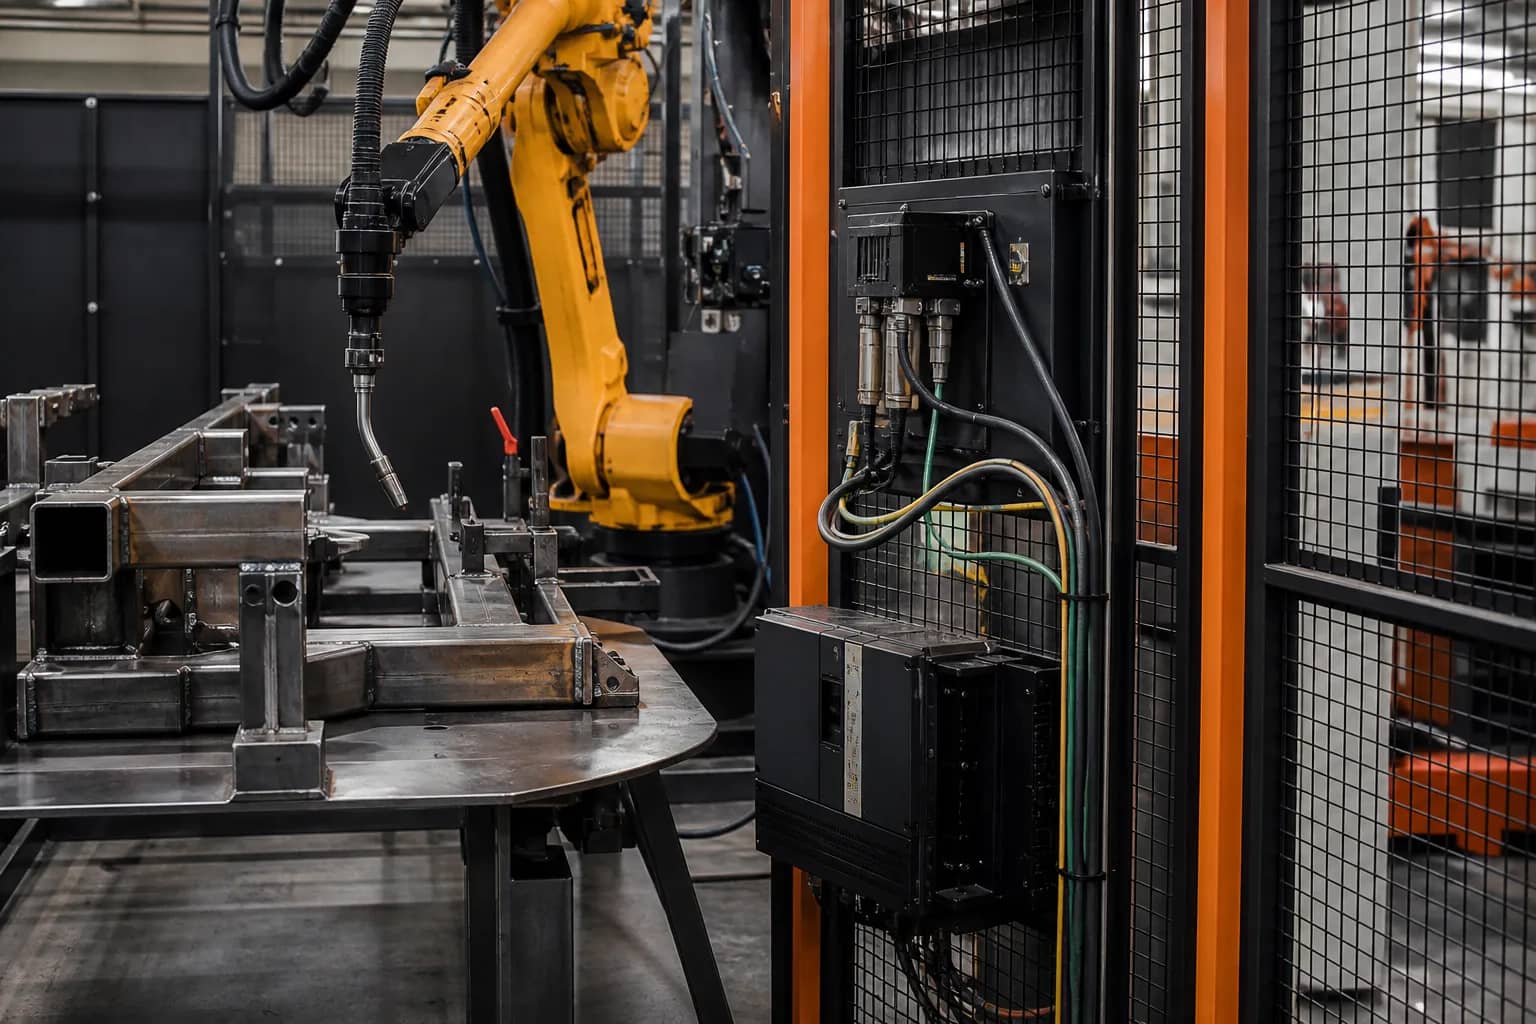
Payload, reach and tool access are checked against the actual workpiece and production target.
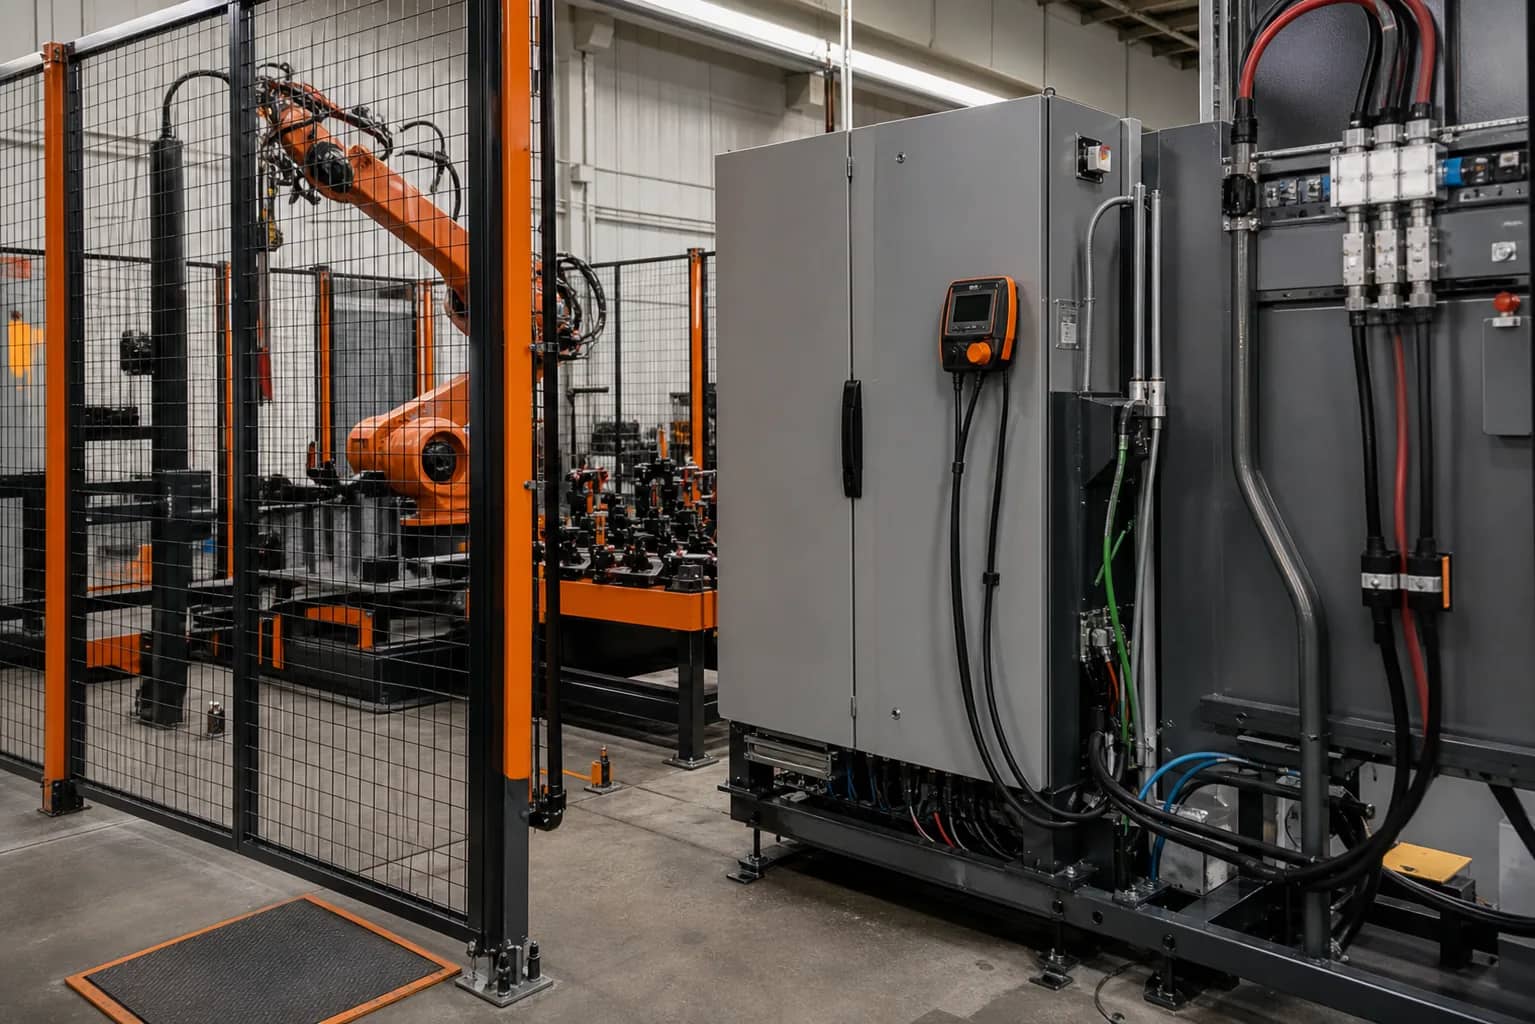
Tooling, workholding, controls, safety and access determine whether the platform becomes productive equipment.
A representative controller option; final compatibility, fieldbus and safety interfaces follow the selected robot and cell. The page is a representative configuration, not a fixed SKU promise. Selection is released only after the application inputs and current manufacturer documentation are reviewed.
Start with the part, process and required result.
Check mass, moments, access, cycle and interfaces.
Confirm current documents, scope and validation gates.
Catalog-based technical path: compare the robot, controller and positioner as one cell decision in the Yaskawa welding cell selection guide →
Configure robot, power source, torch, feeder, fixture, positioner, sensing and safety around the weld and workpiece.
Review application ↗Review total moving mass, center of gravity, moment, reach, throughput and handoff points.
Review application ↗Include the workpiece, gripper, adapters, cables and process tooling—not payload alone.
Prove tool angle, fixture clearance, singularity margin and service access in the actual layout.
Connect motion time, process dwell, sensing and recovery logic to a credible output target.
Define fieldbus, machine handshakes, utilities, guarding and ownership before release.
Send the workpiece, total moving mass including tooling, center of gravity, reach and tool-access requirement, process, target cycle, environment, layout, interfaces, destination and preferred commercial route.
No. It is a representative configuration route. Current availability, compatibility, specification, price and lead time are confirmed against the application and current project documents.
Workpiece geometry, total moving mass, center of gravity, reach and access, process, cycle, environment, interfaces, safety and destination determine the released configuration.
Yes. The reviewed scope may include controller, EOAT, process equipment, workholding, sensing, guarding and adjacent equipment when the required interfaces and responsibilities are defined.
Send drawings or clear photos, material and dimensions, workpiece and tooling mass, process target, cycle or output, layout, utilities, destination and any preferred control or brand standard.
Send the robot and controller nameplates plus required interfaces for a model-specific supply review.