Machine Tending
Select the robot and EOAT from machine interface, door/fixture sequence, payload, reach, cycle and part presentation.
Review application ↗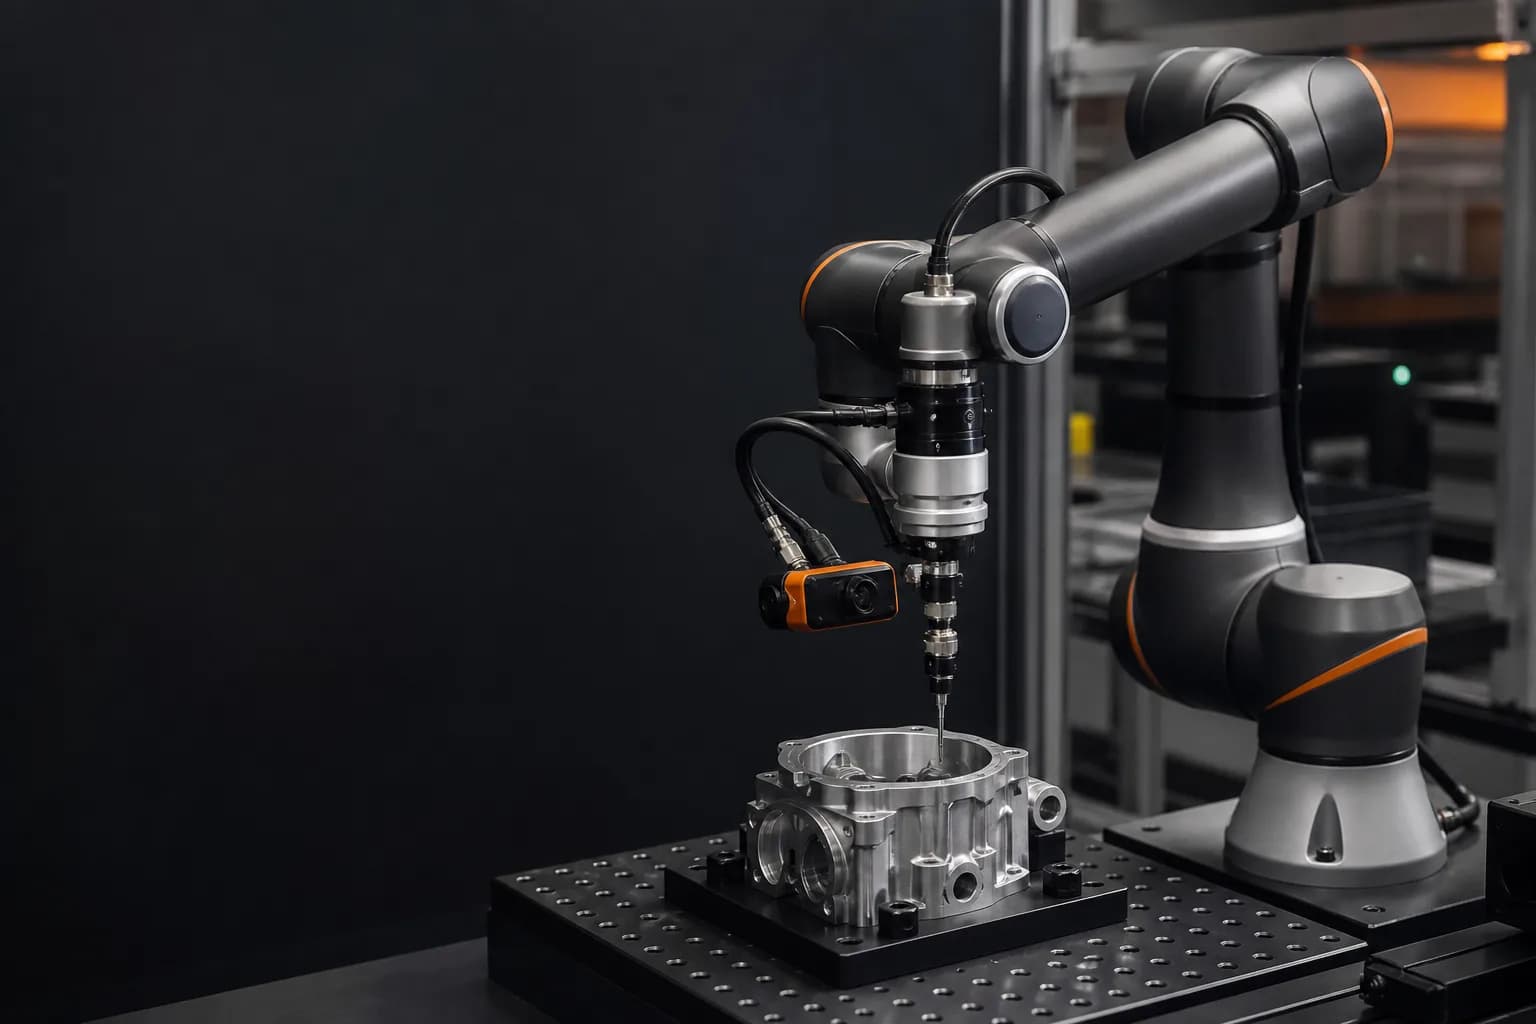
Assess verified RealMan model options for suitable collaborative or specialized applications before confirming supply and integration scope.
A collaborative-robot label does not establish payload, reach, speed, safety assessment, tooling or local service suitability.
Collaborative and specialized robots. TubeFrame Automation reviews current manufacturer documentation and project-specific availability before recommending a model or package.
Select the robot and EOAT from machine interface, door/fixture sequence, payload, reach, cycle and part presentation.
Review application ↗Coordinate tools, compliance, force/torque sensing, vision, fixtures and verification around the assembly process.
Review application ↗Match speed, product variation, detection, gripping and reject handling to an achievable cell concept.
Review application ↗Treat vision as a calibrated process input: part presentation, lighting, tolerance, coordinate frames and recovery all matter.
Review application ↗Workpiece, motion, quality and cycle requirements establish the equipment class.
Payload, reach, mounting, interfaces and environment narrow the viable models.
Region, availability, support route and delivery scope are confirmed before quotation.
Documentation, spares, training and service ownership are recorded in the project scope.
Provide the application, workpiece, total moving mass, reach and access, process, target cycle, environment, destination and any site or preferred-brand standards. We use those inputs to identify a viable platform route and the unknowns that still need validation.
Send the application and destination so current model data and availability can be checked.